Planning a robot take-out conveyor
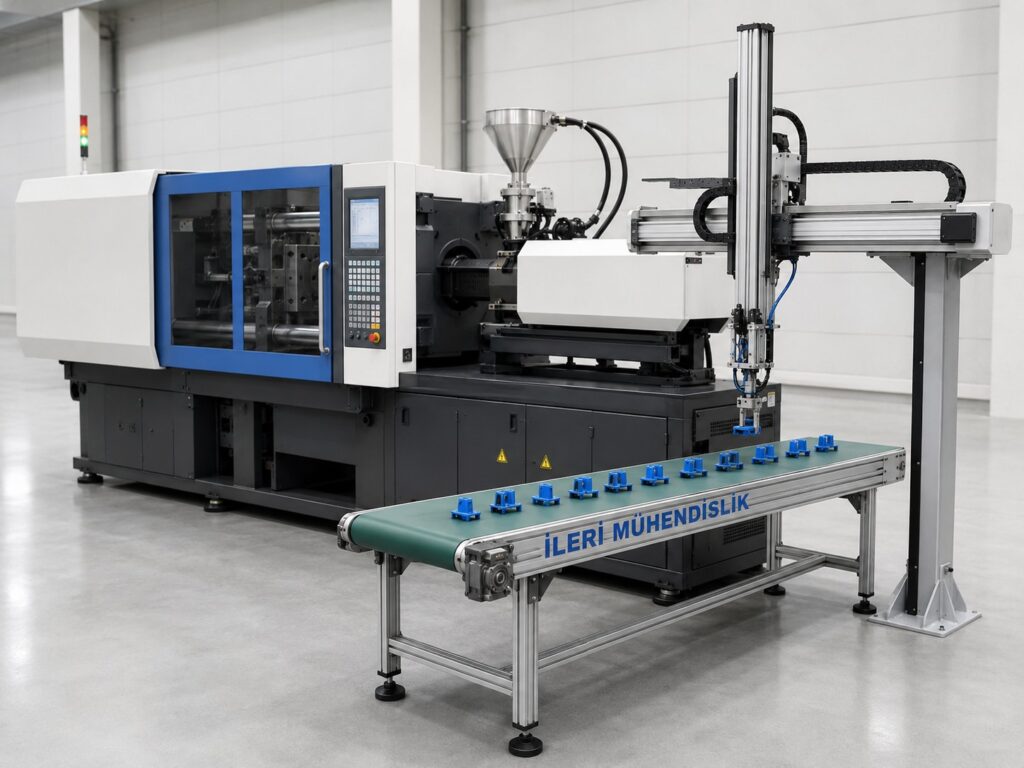
The robot placement pattern sets how much belt area is needed during each cycle. Parts placed in rows occupy a different footprint from parts dropped together.
Map the robot drop coordinates and compare cycle time with the time needed to clear the drop zone. Decide with the integrator whether movement should be continuous or indexed.
Share the intended product orientation and the robot-to-conveyor signal list before the controls are specified.